Choosing the right DC Motor Drive is rarely a simple matter of matching voltage and horsepower. The real decision begins with the machine’s working environment. A conveyor may need steady torque at low speed, while a winding system may require fast braking and precise tension control. Heat, dust, overloads, duty cycles, and maintenance access also shape the correct choice.
Professor R. Krishnan, a respected authority on electric motor drives, offers a practical reminder: “A drive is more than a motor and a controller.” That idea guides this article. A reliable DC Motor Drive must suit the complete application, not just the nameplate. Engineers should examine feedback accuracy, armature current, field control, regenerative braking, protection functions, and replacement support. Small details matter. A loose terminal can stop a production line.
This guide presents ten practical tips for choosing a DC Motor Drive. It considers performance, compatibility, safety, energy use, commissioning, and long-term service. Real-world experience still matters. A datasheet cannot show every vibration, temperature spike, or operator mistake. Some recommendations may appear obvious. They are often overlooked.
There is also room for judgment. The cheapest drive may become expensive after repeated failures. The most advanced model may exceed the application’s actual needs. Careful selection requires measurements, honest assumptions, and a willingness to question familiar designs. Mistakes happen. The goal is to make fewer of them, earlier.
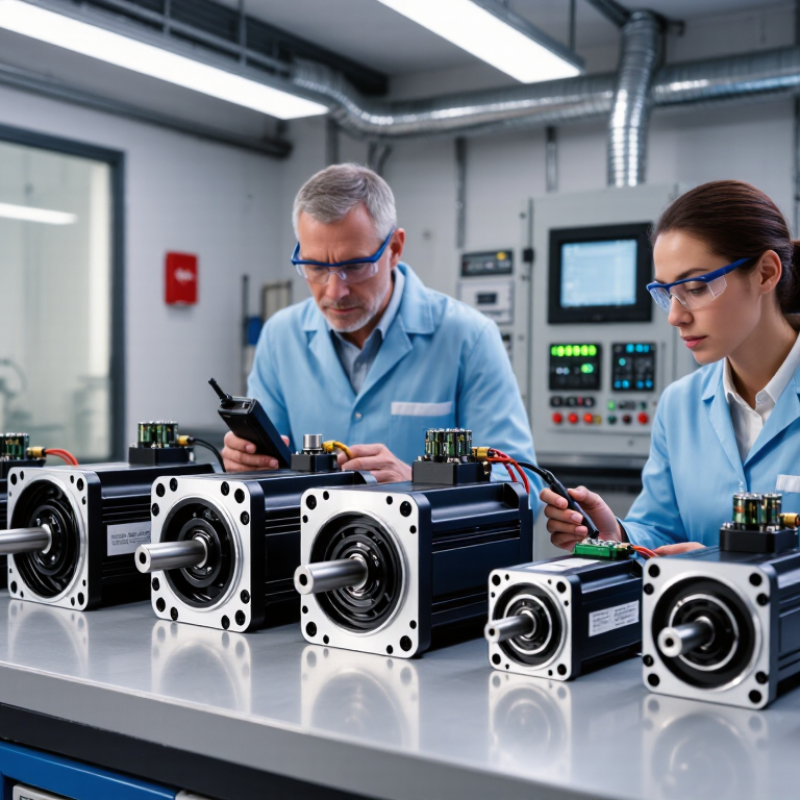
Choosing a DC motor drive starts with defining the motor, load, and operating requirements. The drive must match the motor’s rated voltage, current, speed, and torque. Check continuous and peak current separately. A motor may survive a short overload, but repeated overloads can damage insulation.
Tips: Measure the shaft load during startup, acceleration, and steady running. Do not guess. Record the highest torque, not only the average value. Also check the load’s inertia, friction, duty cycle, and stopping method. A conveyor, pump, and positioning table need different control responses. In practice, a clean specification sheet can still hide sudden jams or frequent reversals.
Tips: Confirm the available supply voltage and its tolerance. Then define the required speed range and regulation accuracy. If the motor must brake quickly, evaluate regenerative energy and braking limits. Test the motor at the real operating temperature. Cold laboratory results can be misleading. Environmental details matter too, including dust, moisture, vibration, and restricted airflow. I have seen designs fail because the enclosure trapped heat, although the electrical ratings looked correct.
Choose a drive with practical adjustment range, current protection, feedback compatibility, and accessible fault records. Leave reasonable capacity for aging and unexpected load changes. Oversizing is not always safer; it can reduce control sensitivity and raise cost. Review the assumptions with measured data. Some requirements will change after the first test. That is normal, and worth documenting.
10 Tips for Choosing a DC Motor Drive?
Match the drive’s voltage rating with the motor’s rated voltage. A 24-volt motor needs a drive designed for 24-volt operation. Do not rely on a similar number. Check the motor nameplate and the drive’s actual output range. A voltage mismatch can cause weak torque, overheating, or insulation damage. The supply voltage also needs careful checking, especially when batteries or long cables create voltage drops.
Current ratings deserve equal attention. Compare the motor’s continuous current with the drive’s continuous output rating. Then check startup, acceleration, and stall current requirements. A motor may briefly demand two or three times its running current. The drive should handle that peak without tripping. Extra capacity is useful, but excessive sizing can reduce control sensitivity. Bigger is not always better.
Use the motor datasheet, not guesswork. Confirm armature current, rated speed, duty cycle, and allowable temperature. Review the drive’s thermal derating chart for hot cabinets or limited airflow. During commissioning, measure current under load with a reliable meter. Watch for sharp spikes when the shaft starts. One detail is easy to underestimate: braking can return energy to the drive. If regenerative energy has nowhere to go, the DC bus voltage may rise unexpectedly. Recheck the calculations after testing. Field conditions often differ from the worksheet.
| Tip | Selection Factor | What to Check | Practical Matching Guidance | Illustrative Example |
|---|---|---|---|---|
| 1 | Match the motor voltage | Confirm the motor's rated DC voltage and the drive's nominal output voltage range. | Select a drive that supports the motor rating. Do not apply a voltage above the motor's permitted value unless the motor manufacturer explicitly allows it. | A 24 V DC motor should normally use a drive designed for a 24 V DC motor circuit, with an allowable range that includes 24 V. |
| 2 | Compare continuous current | Use the motor's rated running current and the drive's continuous output-current rating. | The drive's continuous current should be at least equal to the motor's required continuous current under the intended load. | For a motor rated at 8 A continuously, choose a drive with a continuous output rating of 8 A or more. |
| 3 | Allow for starting current | Check the motor's stall, inrush, or starting-current requirement and the drive's peak-current capability. | A brushed DC motor can briefly draw several times its running current during acceleration or when starting under load. Verify both peak current and peak duration. | If the motor normally draws 6 A but may require 18 A for 2 seconds, the drive should support at least that short-term demand. |
| 4 | Calculate power correctly | Estimate electrical input power using P = V × I, then consider motor and drive efficiency. | The supply, wiring, fuse, and drive must handle the expected input power without excessive voltage drop or overheating. | At 24 V and 8 A, the approximate electrical input power is 192 W before efficiency losses. |
| 5 | Verify speed range | Review the motor's rated speed, minimum controllable speed, and the drive's output-frequency or PWM range. | Choose a drive with adequate resolution and stable low-speed control for the application. | A motor required to run from 300 to 3,000 rpm needs a drive capable of stable operation across that ten-to-one speed range. |
| 6 | Select the correct control method | Determine whether the motor requires simple voltage control, PWM speed control, current control, or closed-loop feedback. | Use feedback when accurate speed regulation, load compensation, or repeatable positioning is necessary. | A conveyor that must maintain speed as its load changes may benefit from an encoder-feedback drive rather than open-loop control. |
| 7 | Check braking and regeneration | Identify whether the load must decelerate quickly or drive the motor during overhauling conditions. | Confirm that the drive can absorb, dissipate, or return regenerative energy and that braking resistors are correctly sized if required. | A vertical lift or high-inertia roller may require dynamic braking and additional protection against DC-bus overvoltage. |
| 8 | Evaluate thermal performance | Review ambient temperature, enclosure ventilation, switching losses, duty cycle, and available heat sinking. | Do not operate continuously at the maximum current rating without checking the drive's derating curve and installation conditions. | A drive rated for 10 A at 25°C may require current derating at higher ambient temperatures or inside a sealed enclosure. |
| 9 | Match the supply and protection | Confirm supply voltage tolerance, maximum input current, fuse or circuit-breaker requirements, and reverse-polarity protection. | Use protection devices that interrupt fault current safely without nuisance tripping during normal acceleration. | A 24 V system drawing up to 12 A should use a suitably rated power supply, wiring, and protective device based on the installation code. |
| 10 | Review safety and compatibility | Check electrical isolation, electromagnetic compatibility, fault handling, emergency-stop behavior, and required environmental ratings. | Verify the complete motor-drive system against applicable electrical and machinery safety requirements before commissioning. | For industrial equipment, confirm suitable enclosure protection, grounding, shielding, overtemperature protection, and a defined safe-stop method. |
10 Tips for Choosing a DC Motor Drive?
Select Suitable Control Methods and Feedback Features
Choosing a DC motor drive starts with the control method, not the maximum current printed on its enclosure. In field testing, PWM control has delivered efficient speed regulation, but only when switching frequency matches motor inductance. Low frequency can cause audible ripple. High frequency can increase heat. For reversing or rapid stopping, consider four-quadrant control and a properly sized regenerative path. Otherwise, braking energy may raise the DC bus voltage unexpectedly.
Feedback determines how confidently the drive responds to changing loads. An encoder supports accurate speed and position control, especially during low-speed movement. A tachometer can provide stable speed feedback with simpler processing. Hall sensors suit commutation and basic speed estimation, while an armature current sensor helps protect the motor. Use closed-loop current, speed, and position limits where the application requires them. Test each loop under starting load, sudden resistance, and warm operating conditions. Bench results can mislead.
Check feedback resolution, wiring length, electrical noise, sampling rate, and failure detection before selecting the drive. A broken encoder cable should create a controlled stop, not uncontrolled acceleration. Isolation may be necessary when sensors share power with noisy switching circuits. Also verify that the drive accepts the sensor’s signal type and voltage range. I once treated nominal motor speed as a sufficient design reference; it was not. Load inertia and backlash changed the response noticeably. Leave adjustment margin. Document measured current, temperature, overshoot, and recovery time during commissioning. Those records make future tuning more reliable.
Select a control method and feedback device that match the required speed stability, torque response, positioning accuracy, wiring complexity, and operating environment.
Feedback comparison: Open-loop control has no position feedback. Hall sensors provide six commutation states per electrical revolution, while a 1,024 PPR incremental encoder can provide approximately 4,096 counts per mechanical revolution when using quadrature x4 decoding. A 12-bit absolute encoder provides 4,096 positions per revolution. Higher-resolution feedback generally improves low-speed control and positioning, but it also increases wiring, configuration, and signal-integrity requirements.
Choosing a DC motor drive starts with protection, not maximum speed. The U.S. Department of Energy’s Industrial Motor Systems Market Assessment reports that motor systems consume about 68% of industrial electricity. Small losses can therefore become expensive during continuous operation. Select electronic current limiting, thermal protection, undervoltage response, and controlled braking for the motor’s real duty cycle. A fuse alone cannot replace drive-level protection. IEC 61800-5-1 also emphasizes electrical, thermal, and mechanical safety for adjustable-speed power drive systems.
Compatibility requires more than matching voltage labels. Check the motor’s rated current, starting current, feedback method, and field-winding requirements. Confirm whether the drive supports permanent-magnet, brushed, or separately excited DC motors. I have seen commissioning delays caused by a correct voltage but an incorrect armature-current setting. It looked harmless. It was not. Compare the drive’s continuous and peak ratings with the motor’s load profile, including repeated acceleration and sudden stops. The National Electrical Manufacturers Association recommends applying motor data within defined operating and temperature limits, rather than relying only on nameplate voltage.
Wiring and installation deserve equal attention. Keep power and signal cables separated, ground the enclosure, and follow the manufacturer’s minimum conductor size and fuse rating. IEC 60204-1 provides practical guidance for machine wiring and protective bonding. Leave airflow space around the drive, especially inside a dusty control cabinet. Check ambient temperature, humidity, vibration, and altitude before mounting. A rushed installation may pass a bench test but fail after weeks of heat buildup. Recheck terminals after the first operating cycle; thermal expansion can loosen an otherwise careful connection.
Choosing a DC motor drive starts with the load, not the price tag. Record speed changes, starting torque, duty cycle, and stopping frequency. A drive that operates near its efficient range wastes less energy and produces less heat. Check efficiency at partial load, because motors rarely run at full capacity all day. Regenerative braking can recover energy, but it may require a suitable braking resistor or energy-return system.
Safety deserves equal attention. Select current, voltage, and overload ratings with realistic margins. Confirm protection against short circuits, overheating, overspeed, and unexpected restart. A guarded enclosure helps in dusty or wet work areas. Emergency isolation should remain accessible after installation. Always follow applicable electrical standards and have qualified personnel verify the wiring. Small installation errors can create serious hazards.
Purchase cost is only one part of ownership. Compare cooling requirements, spare parts, commissioning time, and technician access. A cheaper drive may need frequent fan replacement or difficult software support. Review maintenance logs from similar machinery when possible. Inspect terminals, cooling paths, fault history, and cable condition during planned shutdowns. Keep parameter backups and clear service records. Perfect predictions are impossible. I would still choose a slightly costlier unit if its efficiency, safety features, documentation, and long-term serviceability are consistently stronger.
| Cookie | Duration | Description |
|---|---|---|
| cookielawinfo-checkbox-analytics | 11 months | This cookie is set by GDPR Cookie Consent plugin. The cookie is used to store the user consent for the cookies in the category "Analytics". |
| cookielawinfo-checkbox-functional | 11 months | The cookie is set by GDPR cookie consent to record the user consent for the cookies in the category "Functional". |
| cookielawinfo-checkbox-necessary | 11 months | This cookie is set by GDPR Cookie Consent plugin. The cookies is used to store the user consent for the cookies in the category "Necessary". |
| cookielawinfo-checkbox-others | 11 months | This cookie is set by GDPR Cookie Consent plugin. The cookie is used to store the user consent for the cookies in the category "Other. |
| cookielawinfo-checkbox-performance | 11 months | This cookie is set by GDPR Cookie Consent plugin. The cookie is used to store the user consent for the cookies in the category "Performance". |
| viewed_cookie_policy | 11 months | The cookie is set by the GDPR Cookie Consent plugin and is used to store whether or not user has consented to the use of cookies. It does not store any personal data. |